Agentic embodied navigation
SuperNav
An Agentic Navigation System
for Any Task in Any Scene
TL;DR
- SuperNav is an agentic navigation system for diverse tasks and scenes, from finding objects and visiting multiple targets to fulfilling high-level requests.
- A pretrained multimodal model directs navigation through tool use, task-progress tracking, and context management, without navigation-specific fine-tuning.
- Experiments show higher success rates than the evaluated baselines on single-object, multi-object, and demand-driven navigation, alongside real-world deployment on a quadruped robot.
Real-World Demos
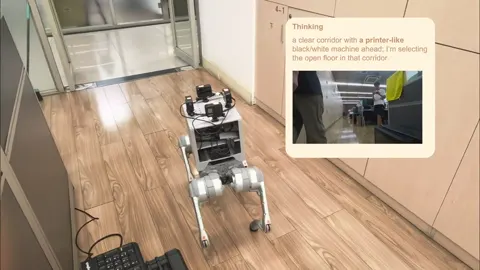
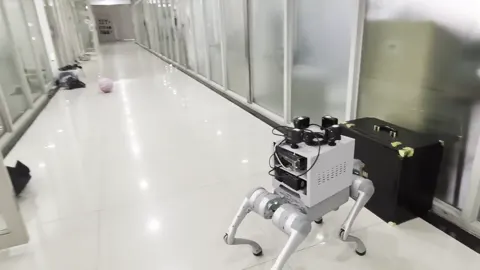
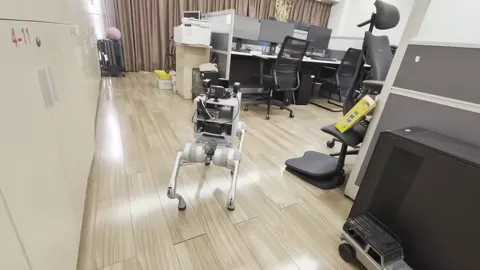
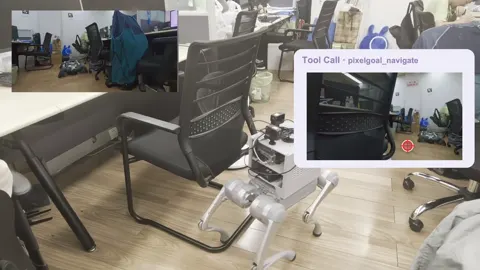
Simulation Demos
Loading video…
Connecting…
Unable to load this video. Open the MP4 directly.
-
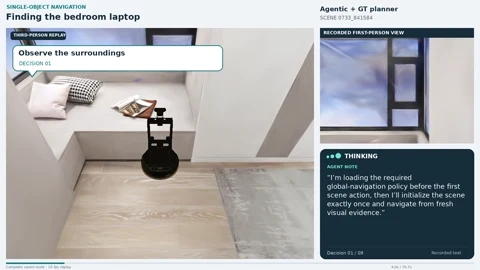 1:10
Find the laptop in the pink bedroomSingle-object · Habitat-GS
-
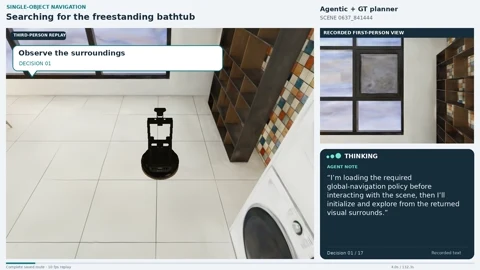 2:12
Find the freestanding bathtubSingle-object · Habitat-GS
-
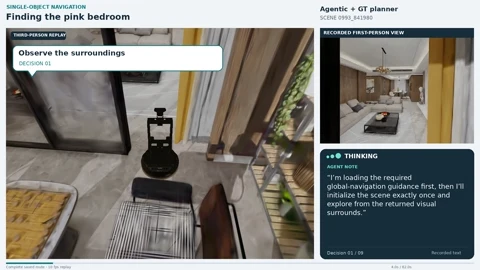 1:22
Find the bed in the pink bedroomSingle-object · Habitat-GS
-
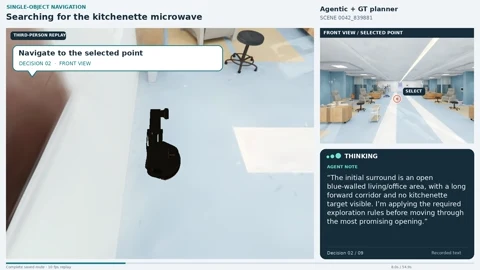 0:54
Find the kitchenette microwaveSingle-object · Habitat-GS
-
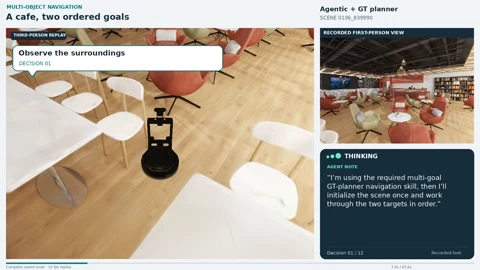 1:05
Find the pastry display and coffee machine in orderMulti-object · Habitat-GS
-
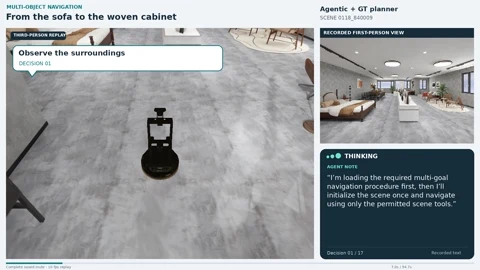 1:34
Find the sofa and woven cabinet in orderMulti-object · Habitat-GS
-
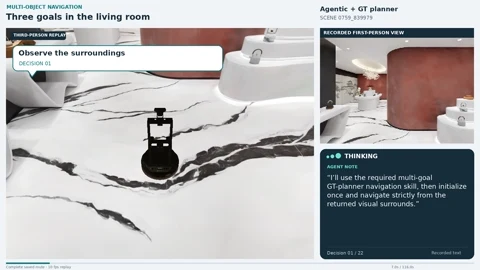 1:56
Find the sofa chair, artwork, and lamp in orderMulti-object · Habitat-GS
-
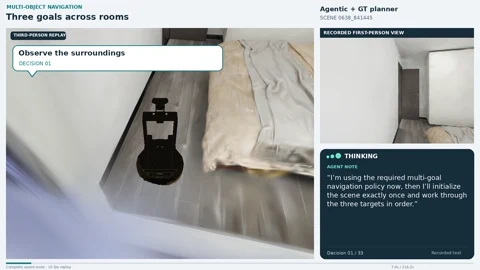 3:36
Find the drawing board, lamp, and shower in orderMulti-object · Habitat-GS
-
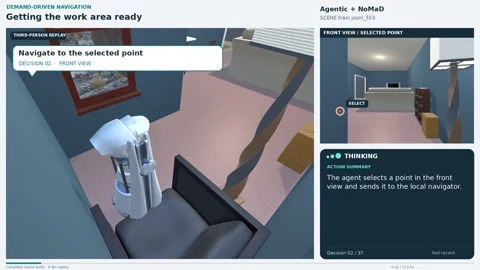 1:53
Help me get the work area readyDemand-driven · AI2-THOR
-
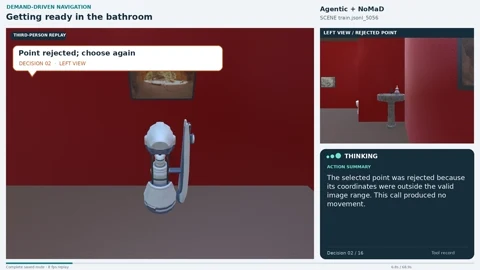 1:08
Help me get ready in the bathroomDemand-driven · AI2-THOR
-
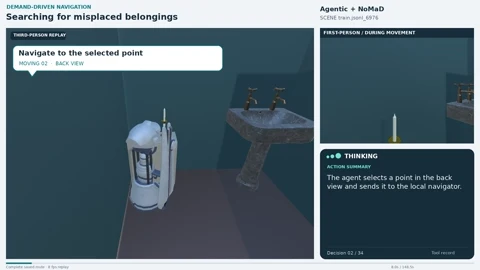 2:28
Help me find my misplaced belongingsDemand-driven · AI2-THOR
-
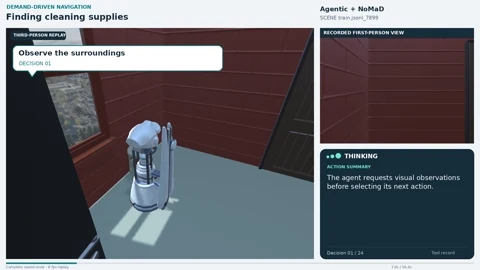 0:56
Help me find cleaning suppliesDemand-driven · AI2-THOR
Method
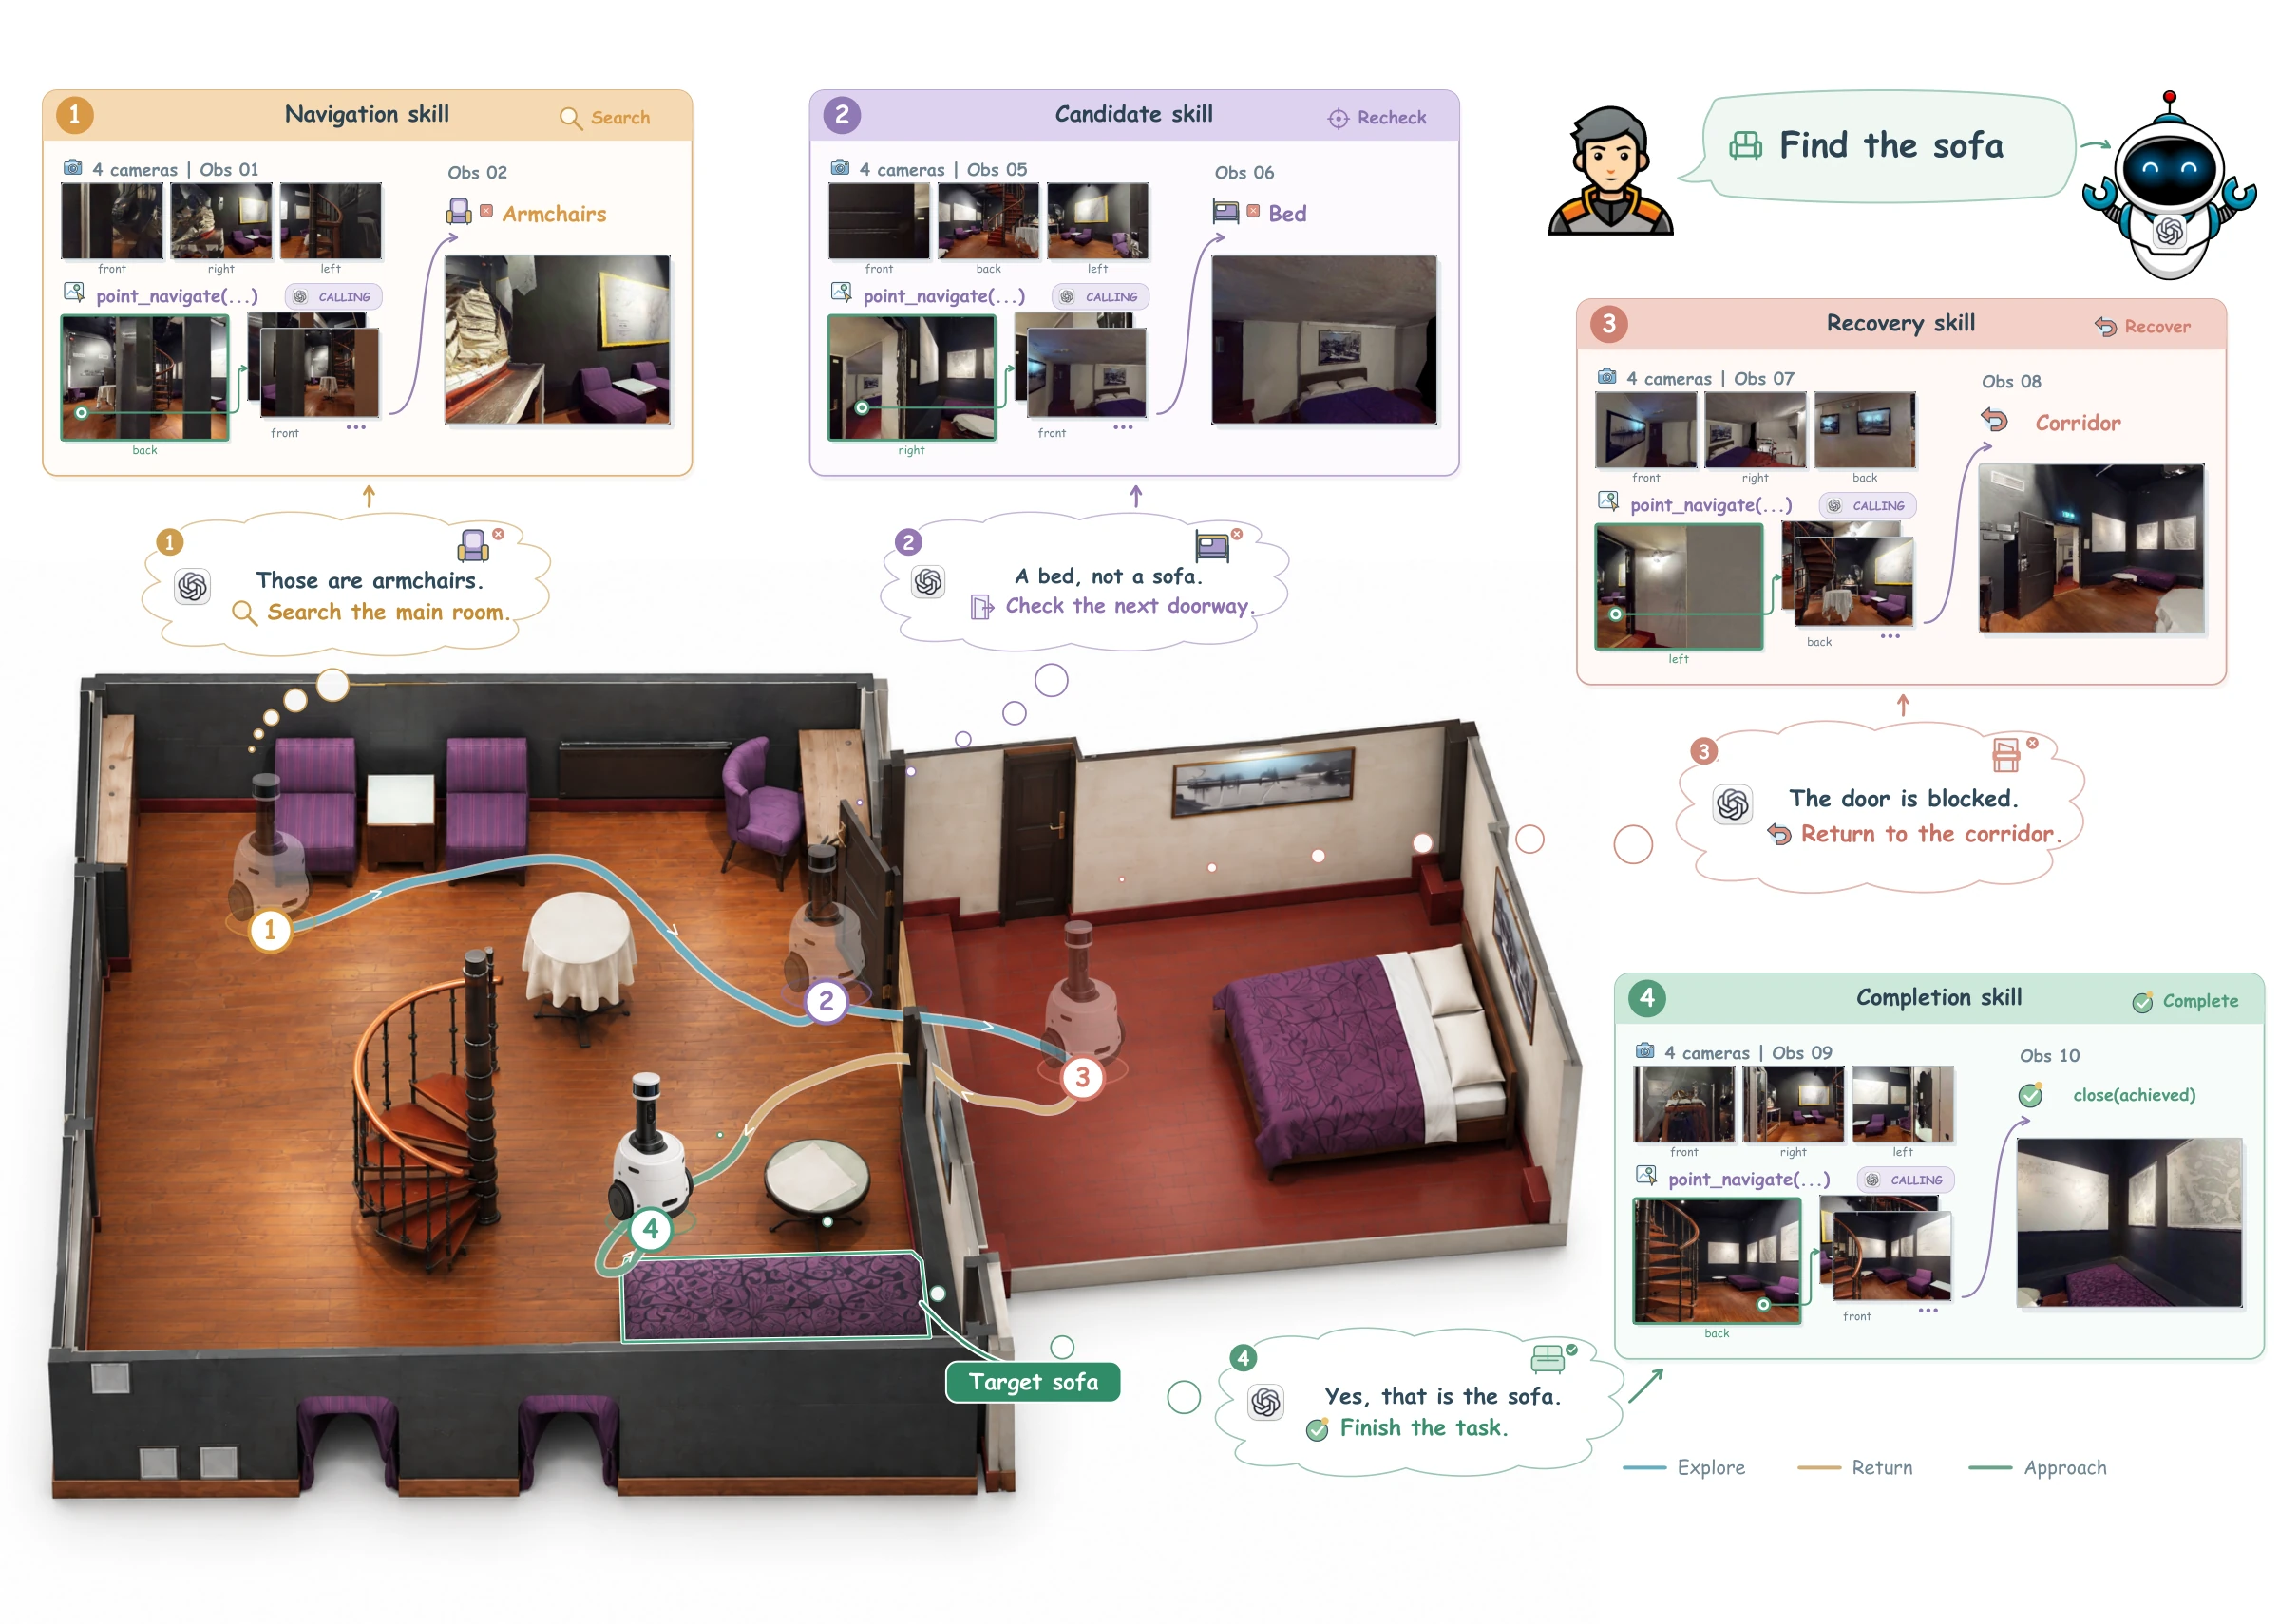
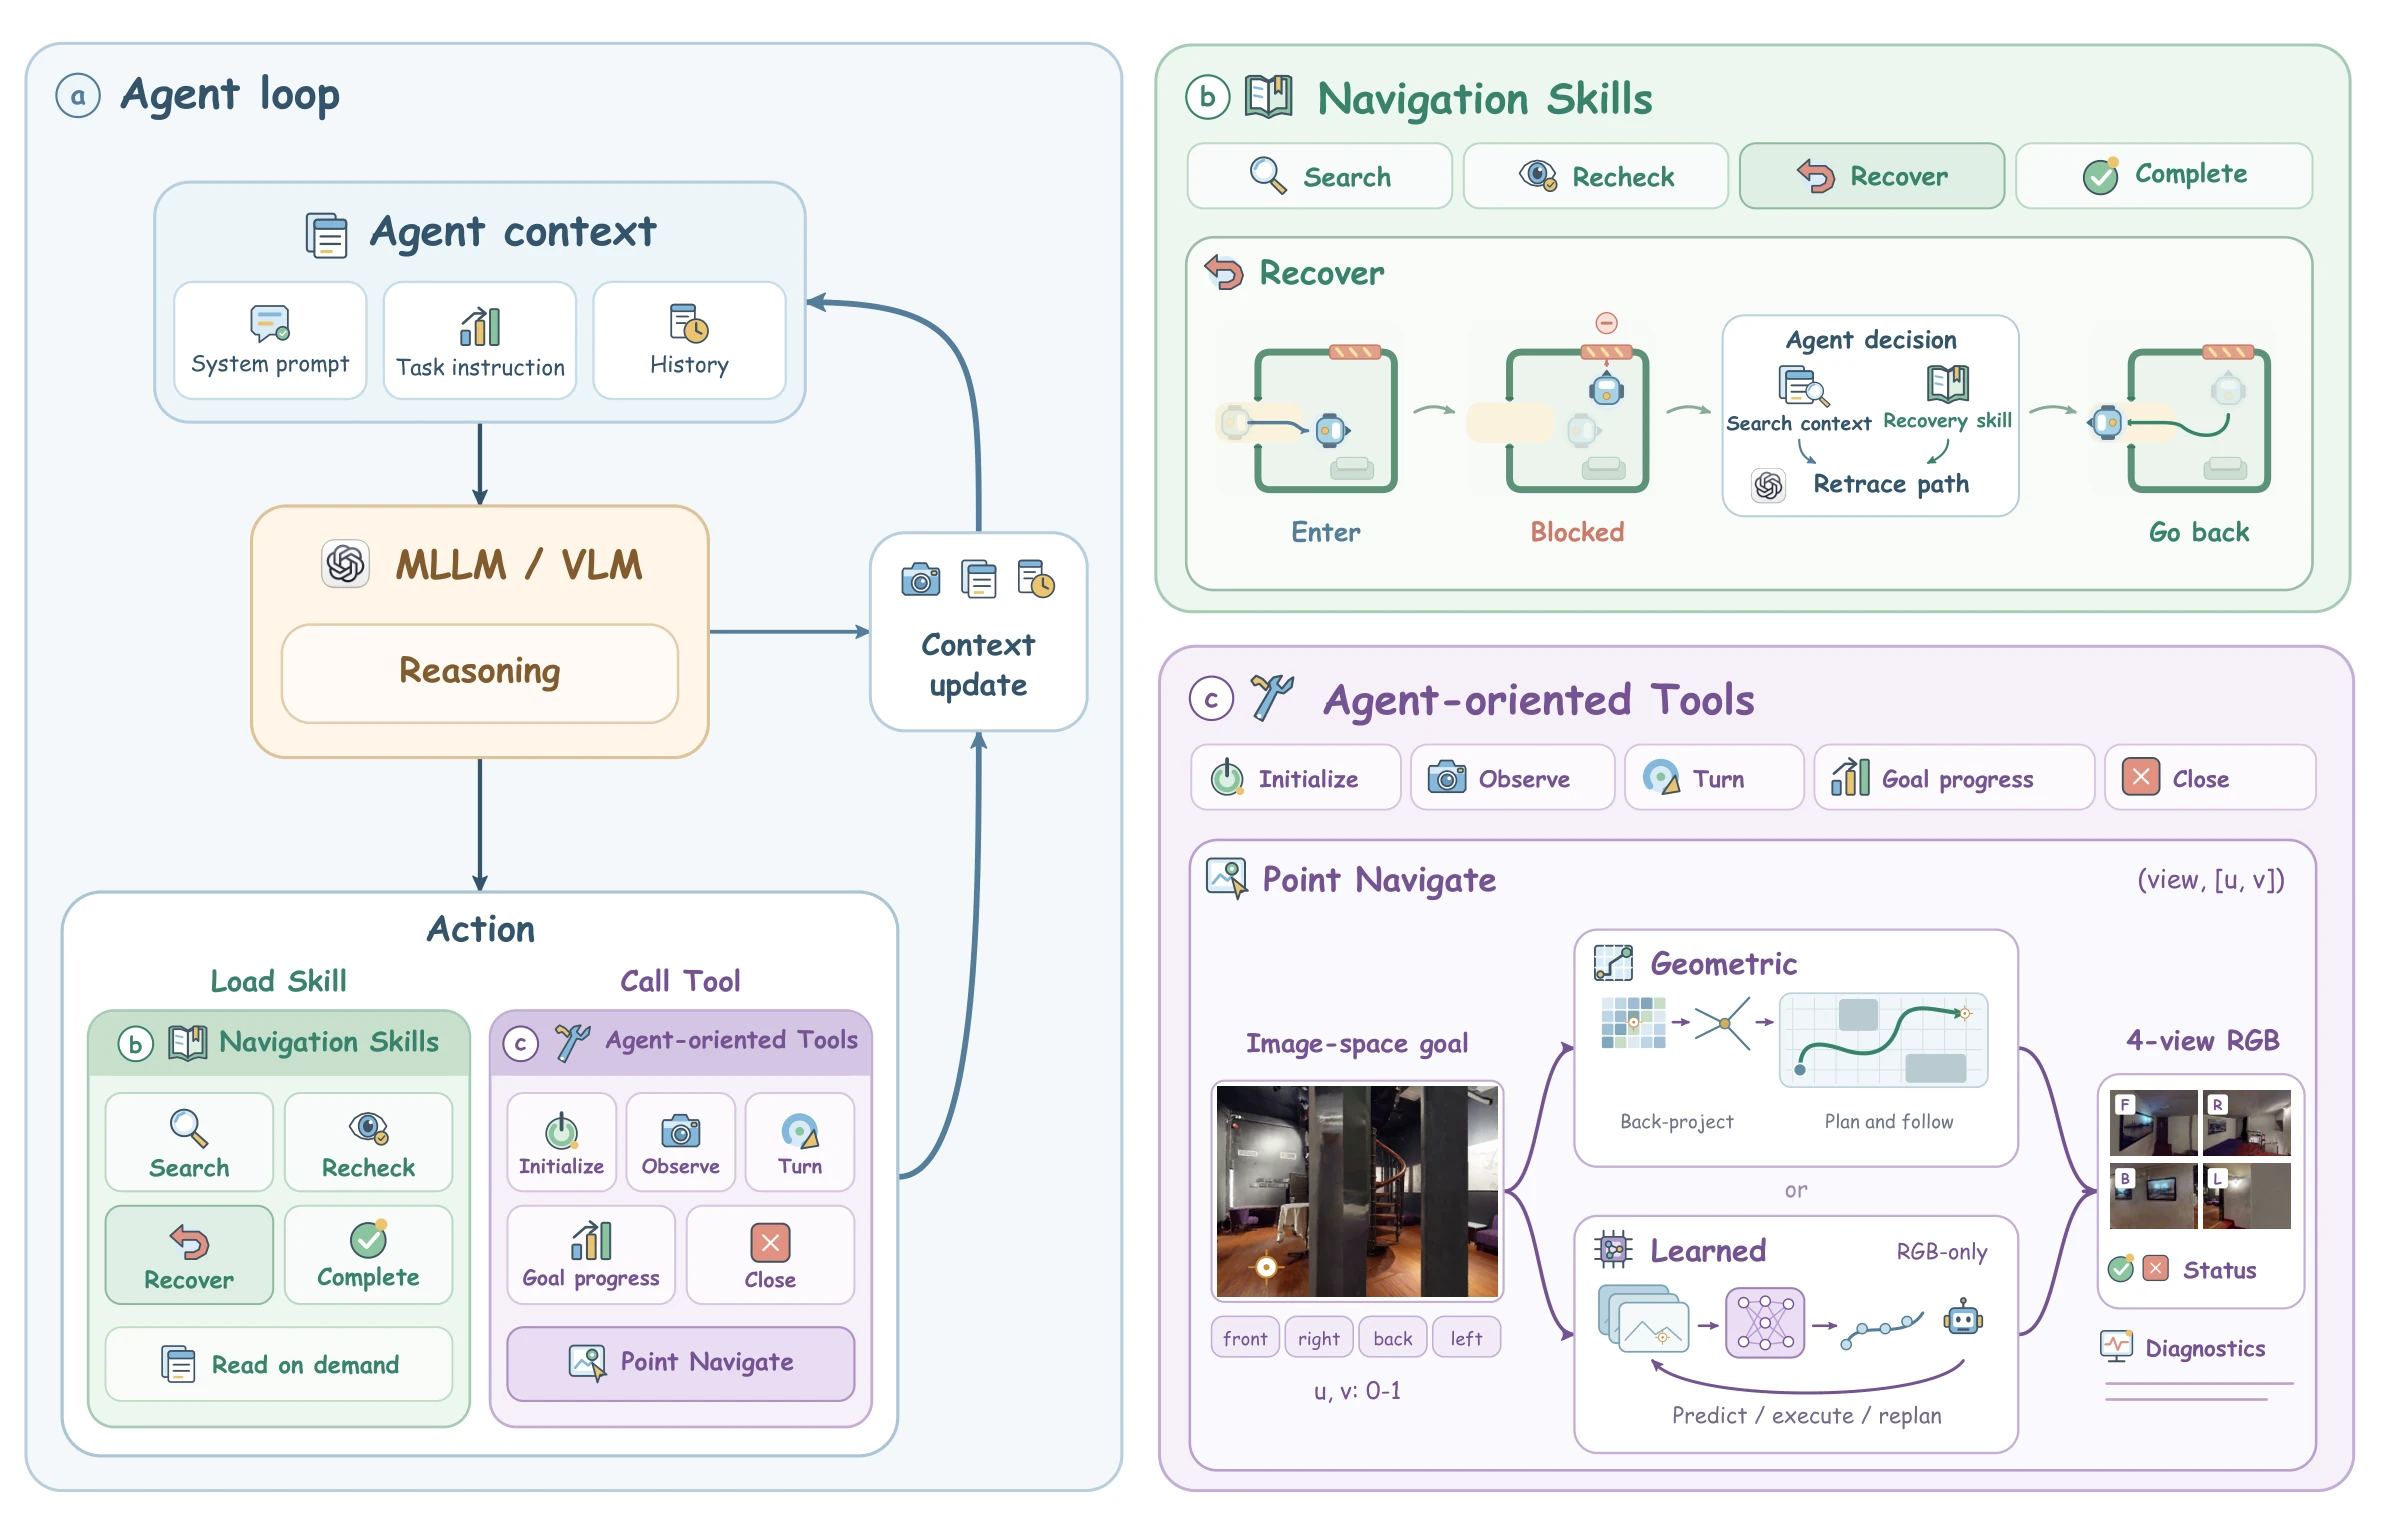
A pretrained multimodal model decides where to go, and SuperNav turns each decision into motion. No navigation-specific fine-tuning.
Results
| Method | SR ↑ | SPL ↑ |
|---|---|---|
| NaVid | 24.67 | 0.1599 |
| UniNaVid | 34.00 | 0.1833 |
| StreamVLN | 13.33 | 0.1036 |
| OmniNav (Action Former) | 27.33 | 0.2133 |
| SuperNav | 78.00 | 0.4127 |
| Method | SR ↑ | SPL ↑ |
|---|---|---|
| NaVid | 2.67 | 0.0216 |
| UniNaVid | 1.33 | 0.0131 |
| StreamVLN | 0.00 | 0.0000 |
| OmniNav (Action Former) | 4.00 | 0.0275 |
| SuperNav | 34.00 | 0.1388 |
| Method | SR ↑ | SPL ↑ |
|---|---|---|
| NaVid | 17.00 | 0.0920 |
| UniNaVid | 25.00 | 0.0943 |
| StreamVLN | 25.50 | 0.0775 |
| OmniNav (Action Former) | 37.50 | 0.1213 |
| SuperNav | 59.50 | 0.1801 |
| Method | 0.25 m | 1 m | ||
|---|---|---|---|---|
| SR ↑ | SPL ↑ | SR ↑ | SPL ↑ | |
| MTU3D | 40.80 | 0.1210 | not reported | not reported |
| SoftNav | 66.70 | 0.2570 | not reported | not reported |
| AstraNav-Memory | not reported | not reported | 62.50 | 0.3490 |
| OmniNav (slow + CoT) | not reported | not reported | 59.20 | 0.3320 |
| SuperNav | 68.33 | 0.3837 | 73.33 | 0.4105 |
| Method | 0.2 m | 1 m | ||
|---|---|---|---|---|
| SR ↑ | SPL ↑ | SR ↑ | SPL ↑ | |
| L3MVN | 36.30 | 0.1570 | not reported | not reported |
| VLFM | 63.60 | 0.3250 | not reported | not reported |
| SG-Nav | 49.60 | 0.2550 | not reported | not reported |
| ApexNav | 76.20 | 0.3800 | not reported | not reported |
| WMNav | not reported | not reported | 72.20 | 0.3330 |
| MSGNav | not reported | not reported | 74.10 | 0.3340 |
| SuperNav | 80.30 | 0.3338 | 86.50 | 0.3638 |
BibTeX
@misc{zhang2026supernavagenticnavigationtask,
  title={SuperNav: An Agentic Navigation System for Any Task in Any Scene},
  author={Jinkai Zhang and Jingyi Xu and Yuanhong Yu and Jiarui Guo and Ruizhen Hu and Hujun Bao and Xiaowei Zhou and Sida Peng},
  year={2026},
  eprint={2610.12126},
  archivePrefix={arXiv},
  primaryClass={cs.RO},
  url={https://arxiv.org/abs/2610.12126},
}